Say Goodbye to the "Mechanical Drag" Feeling: How DNCS Redefines the Consumer-Grade Exoskeleton with Cutting-Edge AI Algorithms?
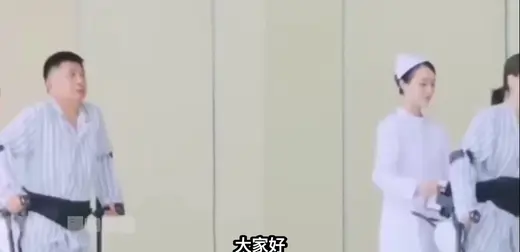
Have you ever experienced this: you wear a heavy lower-limb exoskeleton loaded with motors and a high-energy battery to go hiking. You expect to feel like walking on flat ground, but instead, the motor fails to anticipate your intent, playing a tug-of-war with your muscles at every step?
This counter-intuitive lagging and dragging sensation is the ultimate Achilles' heel restricting the widespread adoption of the consumer-grade exoskeleton. Resolving this pain point is not fundamentally about launching a mere "material war" of piling on carbon fiber and servo motors; it is an "perception war" that requires grinding away at algorithms.
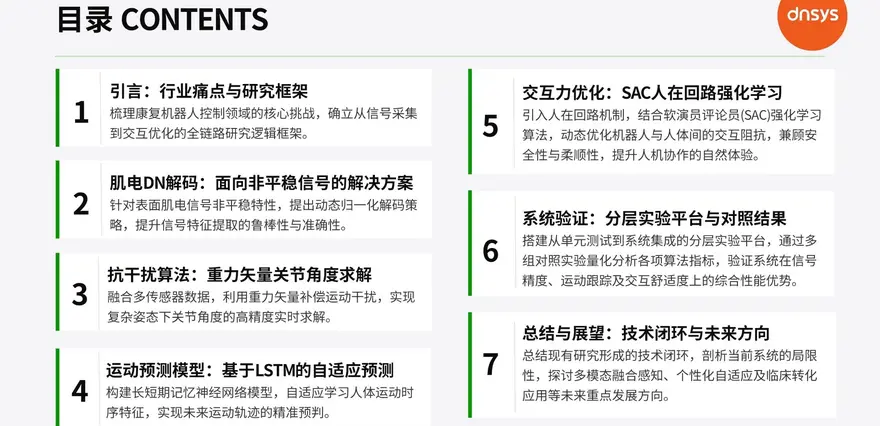
Recently, a deep-dive, hardcore presentation on the "Key Technologies for Human-Robot Integration of the Assistive Exoskeleton" unveiled the underlying logic for breaking this bottleneck. DNCS and the full-chain, end-to-end deep adaptive learning loop they proposed are attempting to fundamentally resolve the "acclimatization issues" of traditional assistive exoskeletons.
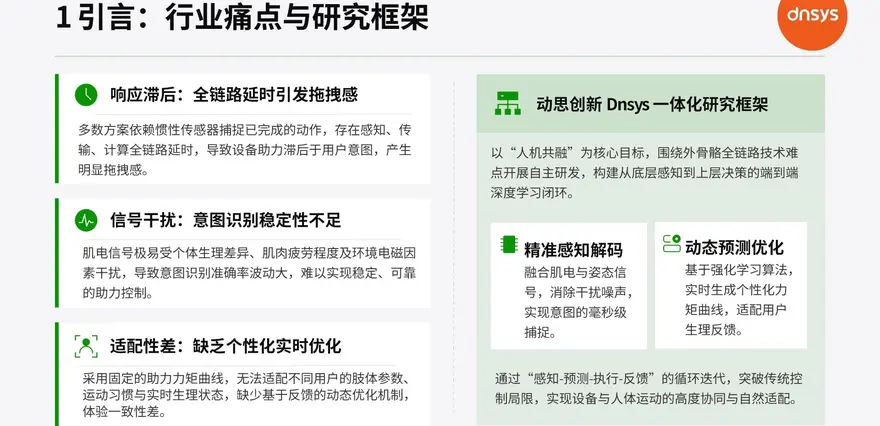
Pain Points: Why Does Your Lower-Limb Exoskeleton Always Seem to Sabotage You?
In today’s consumer-grade and even broader commercial exoskeleton arenas, regardless of whether the form factor is a waist-mounted belt for lumbar / back assist or a leg sleeve delivering hip assist, the word that keeps popping up in user feedback is “drag-along.”
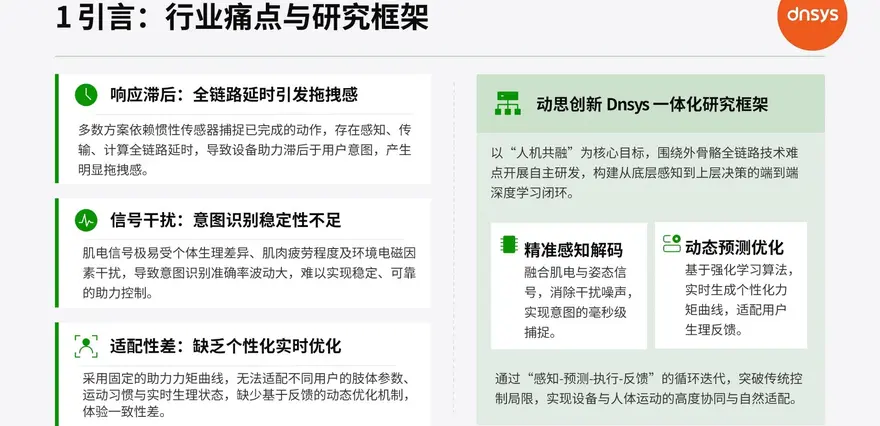
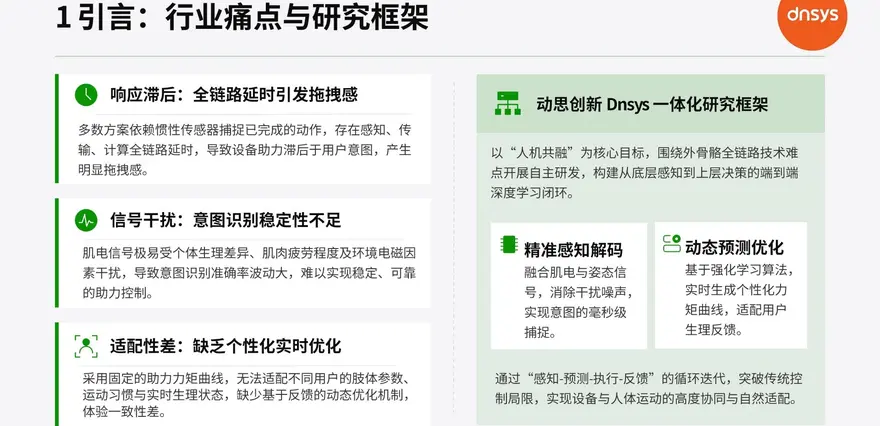
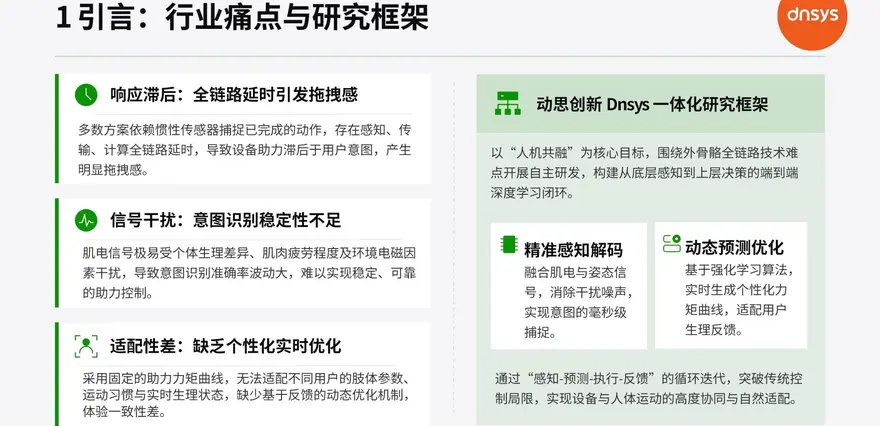
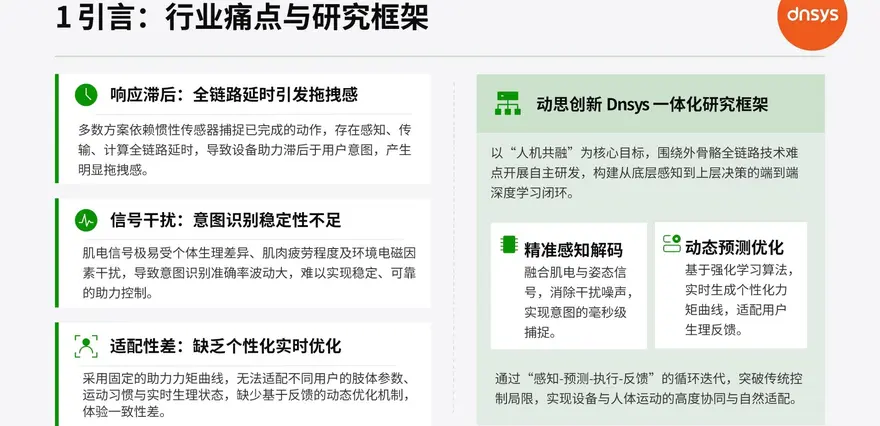
Legacy lower-limb exoskeletons operate on a one-way, closed chain of lag: sensor capture → control-board computation → servo-motor actuation.
“Conventional gear can only ‘see’ that you’ve already lifted your leg after the fact. The full-loop latency from perception, transmission, and calculation to motor actuation means the boost never catches up with your body’s real-time motion intent.” (cited in the video)
That latency causes the sensation of being dragged, which not only spoils the user experience but also heightens physical energy expenditure. Besides simply “slow,” the industry wrestles with two more non-negotiable pain points:
- Intent recognition is extremely unstable. Electromyographic (EMG) signals fluctuate wildly with individual physiology, muscle fatigue, and even ambient electromagnetic noise, leading to assist forces that surge and drop abruptly, producing the jittery “start-stop” feel.
- One-size-fits-all simply doesn’t fit all. Many commercial devices ship with hard-coded assist curves baked in at the factory, offering little to no adaptation to users’ distinct limb dimensions, movement styles, or varying fatigue levels.
A Breakthrough Approach: The Dual-Pronged Strategy of the DNCS Human-Machine Integration Framework
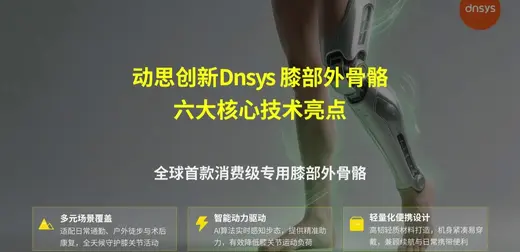
To address the pain points mentioned above, Dnsys has proposed an integrated solution with "human-machine integration" as its core objective. Its core philosophy can be summarized as a closed loop that breaks the limitations of traditional, one-way, passive control:
"The entire system relies on the continuous, cyclical iteration of perception, prediction, execution, and feedback to achieve a high degree of synergy and natural adaptation between the device and the human body." (Mentioned in the video)
Under this overarching framework, the entire system is ingeniously broken down into two core modules:
The first is the "Precise Perception & Decoding" module. It completely discards the limitations of a single sensor, deeply fusing both EMG and posture signals. Through high-dimensional algorithms, it eliminates various environmental and physiological noise, achieving millisecond-level capture of the body's deeper movement intentions.
The second is the "Dynamic Prediction & Optimization" module. It leverages reinforcement learning algorithms, combined with the user's real-time physiological feedback data (such as muscle activation levels), to dynamically generate personalized joint torque curves tailored to the user's current state.
This enables the exoskeleton to be no longer a rigid "suit of armor" with interlocking, stiff gears, but rather a "symbiote" with foresight and dynamic softness. Next, we will deconstruct this closed loop along the industry chain to see how it is implemented at both the code and hardware levels.
Caption: A panoramic view of Dnsys's system architecture, fully illustrating the signal flow and the allocation of algorithm layers. (Mentioned in the video)
Core Algorithm 1: Taming the "Drifting" Electromyography Signals with a Convolutional Autoencoder
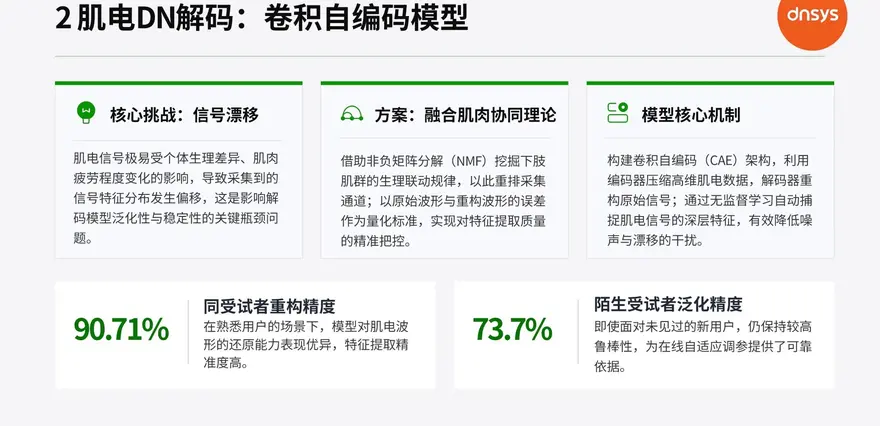
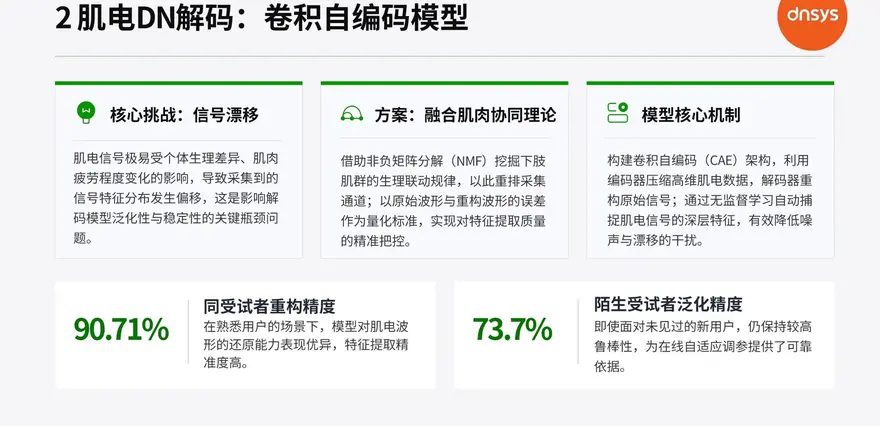
To achieve precise intent capture, the first step is to address the inherent flaw of electromyography (EMG) signals: "non-stationarity." During physical activity, human sweating and muscle fatigue cause severe shifts in the feature distribution of EMG signals.
"Human EMG signals exhibit feature distribution shifts due to individual physiological differences and varying muscle fatigue levels during movement. This is also the bottleneck limiting the weak generalization capability of traditional decoding models." (Mentioned in the video)
To tackle this tricky "drifting and shifting" problem, the first card DNCS played is the "EMG-DN Decoding" technology:
First, the team cleverly introduced the muscle synergy theory, utilizing Non-negative Matrix Factorization (NMF) to uncover the physiological linkage patterns of lower-limb muscles, thereby guiding the optimal arrangement of EMG acquisition channels.
Second, they constructed an elegant "Convolutional Autoencoder (CAE) architecture." The encoder acts like a juicer, compressing high-dimensional, noise-filled EMG data; the decoder, like a filter, focuses on restoring the purest original physiological signal features.
This unsupervised learning architecture delivered extremely impressive data results in actual testing:
"For the same participant, the waveform reconstruction accuracy reached 90.71%; even when faced with a new user whose data was never collected, the generalization accuracy remained at 73.7%." (Mentioned in the video)
This means that in the future, when an ordinary consumer purchases an exoskeleton, they will not need to undergo a complex "motion calibration" process lasting up to half an hour. With just a few dozen seconds of data warm-up, the device can quickly recognize the new user's force-generation habits through online adaptive adjustment.
Caption: Comparison of signal denoising between the Convolutional Autoencoder (CAE) model and traditional filtering algorithms. The left image shows the raw EMG signal filled with noise, and the right image shows the smoothed waveform reconstructed by the CAE. (Mentioned in the video)
Caption: Visualization of feature extraction of physiological linkage patterns in lower-limb muscles using Non-negative Matrix Factorization (NMF). (Mentioned in the video)
Caption: Thermal map distribution of the algorithm achieving 73.7% accuracy for new users (generalization testing). (Mentioned in the video)
Core Algorithm 2/3: Gravity Vector Solving + LSTM – Eliminating the Ultimate "Lag"
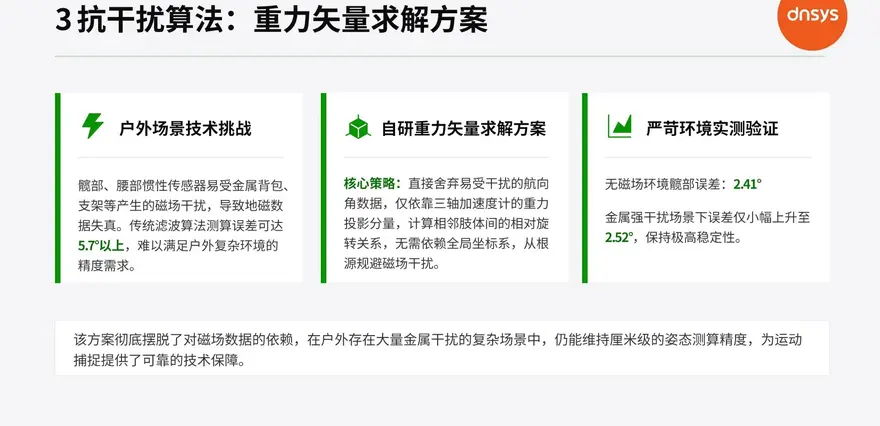
If sEMG / EMG decoding is the nervous system, then posture sensing is the vestibular system. In general outdoor scenarios, such as hiking or trekking, the IMU sensor mounted on the exoskeleton waist belt or leg straps is highly susceptible to environmental interference.
"Widely distributed inertial sensors mounted on the waist belt and legs are easily subject to magnetic interference from metallic objects like metal backpack frames and metal supports, causing distortion in geomagnetic data acquisition. Traditional filtering algorithms simply cannot handle this." (Mentioned in the video)
To address this pain point, DNCS abandoned the conventional approach that over-reliance on the geomagnetic sensor requires and innovatively proposed a "gravity vector solving methodology". By introducing the gravity vector as a natural absolute reference frame and fusing temporal data from multiple sensors, the system can calculate the joint angle with high precision, even in a complex outdoor magnetic environment surrounded by reinforced concrete or rock walls. It keeps the measurement error at an extremely low level, breaking through the error limits of more than 5.7 degrees seen in traditional algorithms.
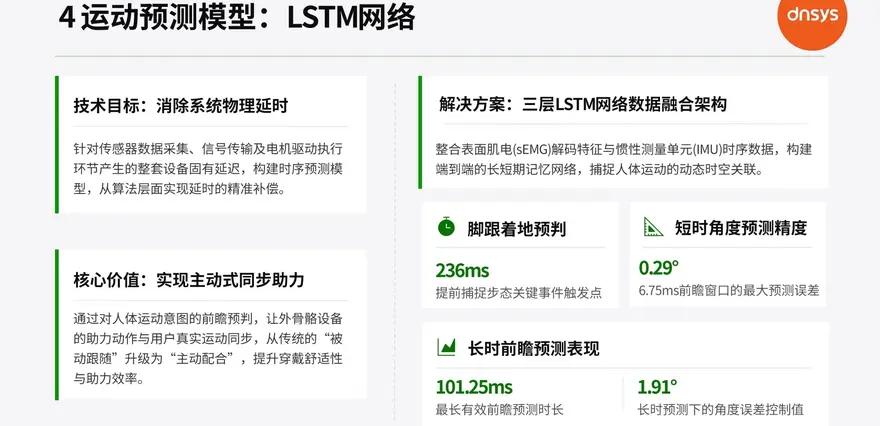
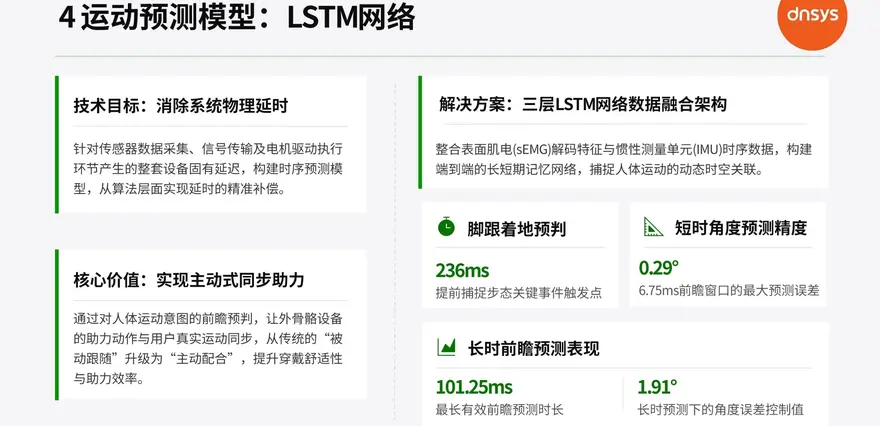
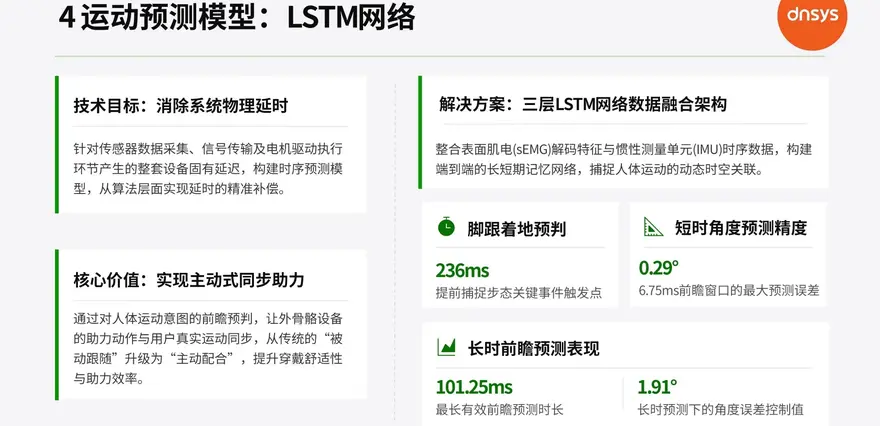
Once high-precision joint angles are obtained, a new problem follows: the execution latency of hardware actuators still exists. To solve this, DNCS introduced a temporal prediction large model based on LSTM.
The core value of this algorithm lies in "prediction". It acts like a gaming opponent in your brain, deeply mining the temporal characteristics of the human body's past movements to preemptively predict your motion trajectory half a second in advance.
"The system preemptively predicts the motion trajectory, completely offsetting the hardware system delay and fundamentally ensuring a highly synchronized human-machine motion." (Mentioned in the video)
When you just have the conscious intent to lift your leg, the hip assist module of the exoskeleton has already output torque to the predetermined angle, completely eliminating that rebound dragging sensation of being "pulled back by your pants leg".
Caption: Comparison of the joint angle error between the gravity-vector-based anti-interference algorithm and the traditional filtering algorithm under outdoor magnetic interference. (Mentioned in the video)
Caption: Simulation of temporal prediction for the human body's future motion trajectory within a gait cycle using LSTM. (Mentioned in the video)
Caption: Comparison between a traditional "perception-execution" lagged feedback link and DNCS's "perception-prediction-execution" forward-looking control link. (Mentioned in the video)
Caption: Hardware architecture of a high-performance servo motor output module equipped with a precision transmission mechanism. (Mentioned in the video)
Core Algorithm 4: SAC Reinforcement Learning—Let Everyone Have Their Own Custom "Torque Curve"
Having solved the issues of speed and accuracy, Dnsys now directs its focus toward the ultimate interactive experience: compliance.
Traditional fixed assist modes are akin to having a constant-power, fixed-frequency motor installed. Whether you are taking a light walk or engaging in a heavy trekking assist with a 30 kg load, the assist force it provides remains rigidly consistent.
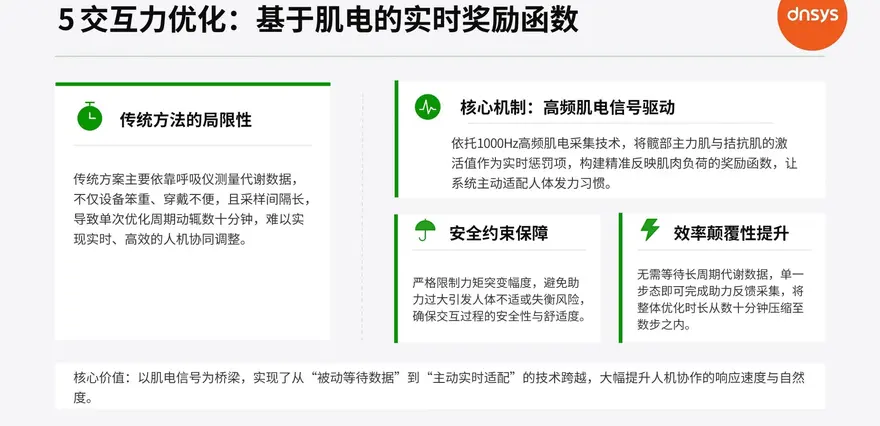
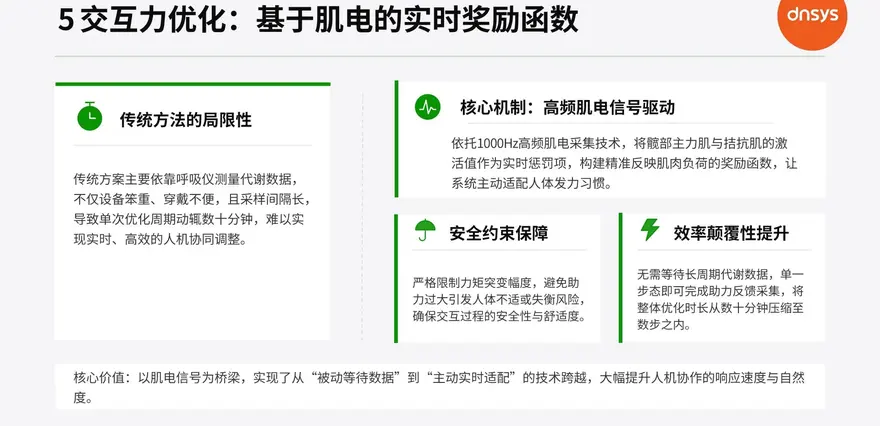
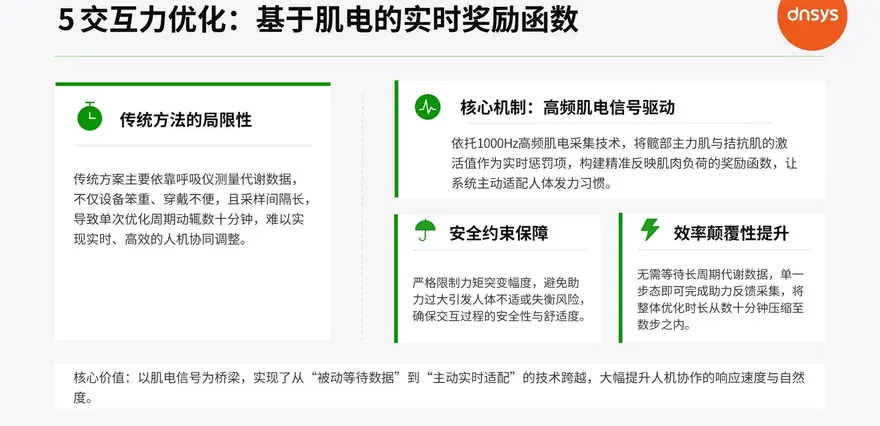
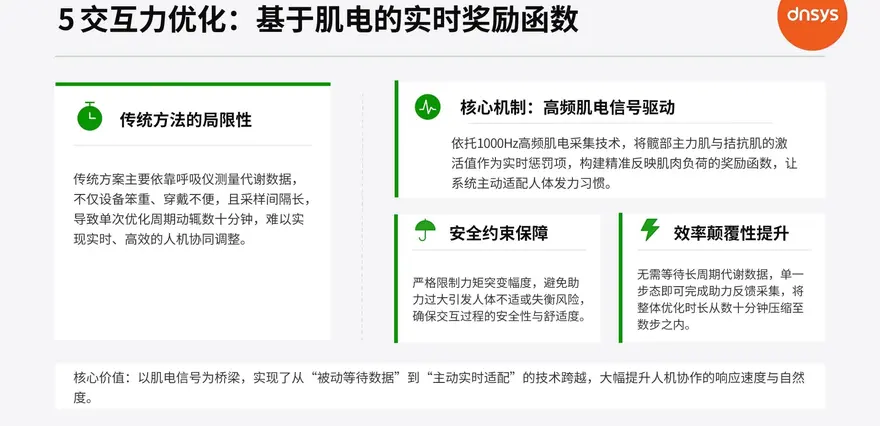
To address this, Dnsys offers a solution: Dnsys deploys a SAC (Soft Actor-Critic) reinforcement learning algorithm based on real-time electromyography (EMG) feedback in the upper control layer, enabling "human-in-the-loop" interactive force optimization.
"Because it is equipped with the SAC reinforcement learning algorithm, the system can rely on real-time muscle activation data to dynamically generate a personalized assistive torque tailored to each individual." (mentioned in the video)
The most fascinating aspect of this algorithm is its "breathing" effect. When you first start hiking with ample muscle strength, the algorithm maintains a lower level of assist. As you climb for two hours and your quadriceps begin to fatigue—causing EMG signals to weaken—the system keenly captures this fatigue threshold and immediately increases the motor's joint torque output to compensate for your diminishing muscle strength.
Meanwhile, the interaction resistance between the human and the machine is dynamically adjusted to an incredibly delicate "equilibrium point.Balancing absolute safety with extreme compliance," this algorithm transforms the exoskeleton from a blindly brute-force mechanical machine into an add-on exoskeleton that understands your fatigue and knows when to push forward or pull back.
Caption: Neural network training model diagram of the SAC (Soft Actor-Critic) reinforcement learning algorithm. (mentioned in the video)
Caption: A real-time output comparison between the dynamically generated personalized assistive torque curves and traditional fixed torque curves under different load capacities. (mentioned in the video)
Caption: A flowchart demonstrating the SAC algorithm's adaptive assist adjustment in response to weakening EMG signals under varying fatigue states. (mentioned in the video)
Caption: Numerical monitoring of the dynamic mapping relationship between the exoskeleton's internal algorithmic layers and human muscle activation levels. (mentioned in the video)
System Validation: The Hardcore Strength Behind Three Controlled Experiments
Talking about algorithms on paper is futile; we must let data from strictly controlled experiments speak for itself. The presentation detailed a rigorously designed set of three experiments, demonstrating a paradigm-shifting advantage over traditional solutions in both energy efficiency and user experience.
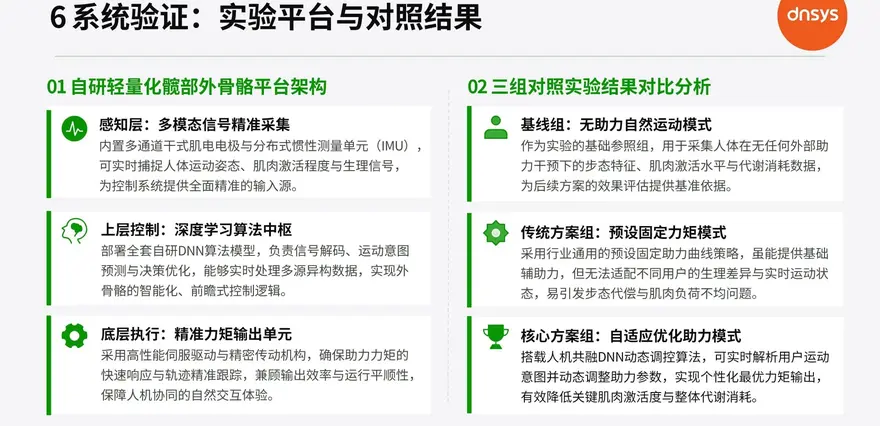
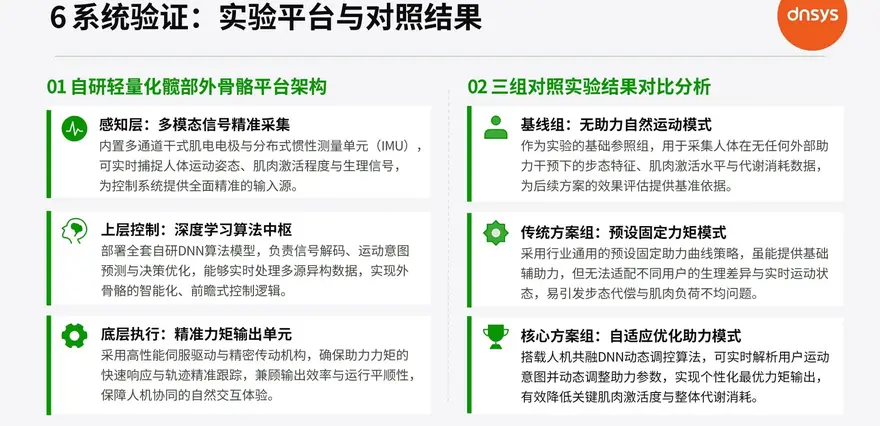
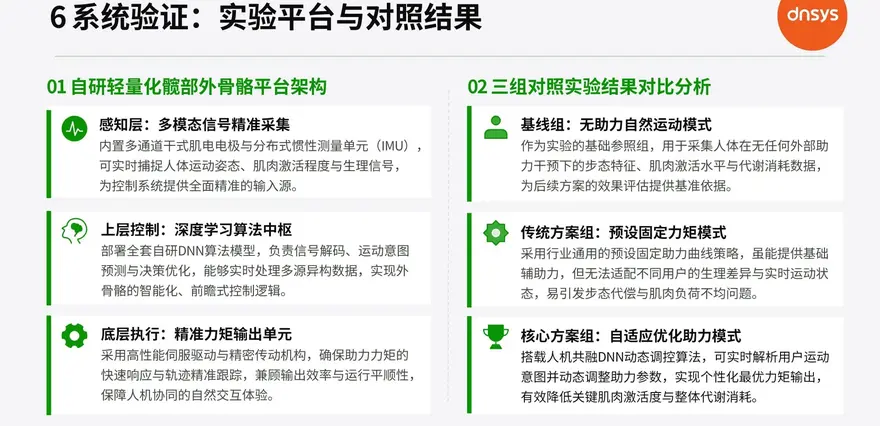
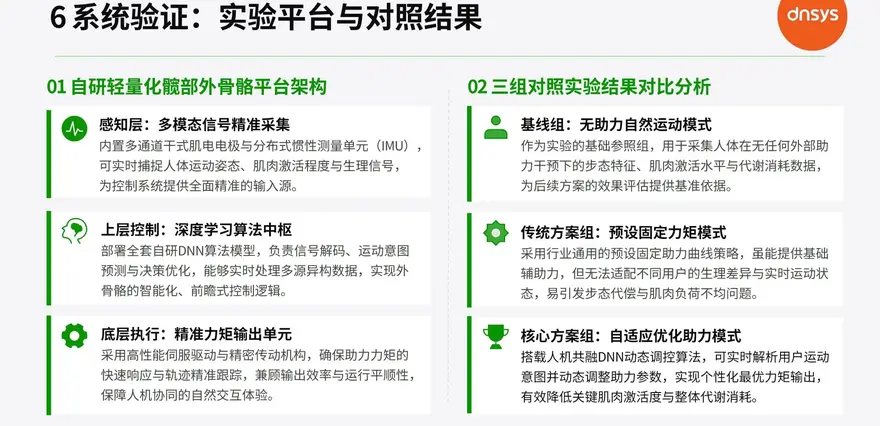
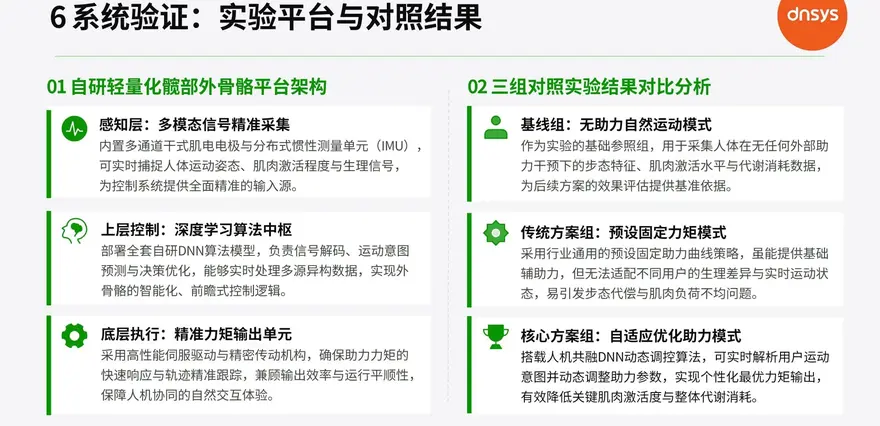
The first group was the bare-bones control group. Subjects did not wear any exoskeleton devices, instead using only a distributed IMU array to synchronize and collect natural gait data, muscle activation levels, and metabolic consumption. This served as the golden baseline reference for the entire evaluation.
The second group utilized a traditional solution. This involved an industry-standard preset, fixed joint torque mode. The experiment confirmed that while such devices can output a basic assistive force, they are highly prone to causing compensatory movements when faced with the physiological differences of various users. This leads to a severe uneven distribution of local muscle load, resulting in an out-toeing gait or knee soreness.
The third group employed the core DNCS solution. In this closed-loop system, the foundational perception layer integrates distributed IMUs and fabric pressure sensors, responsible for continuously collecting multimodal physiological signals. The middle layer deploys a complete set of in-house deep neural network algorithm hubs to uniformly handle signal decoding and intent prediction. The execution layer utilizes high-performance servo motors and a precision transmission mechanism to ensure smooth joint torque output.
The final experimental conclusions were highly significant:
“A system equipped with the complete DNCS algorithm can analyze dynamic motion intent in real-time, significantly reducing the activation level of key human muscles and overall energy metabolic consumption.” (Mentioned in the video)
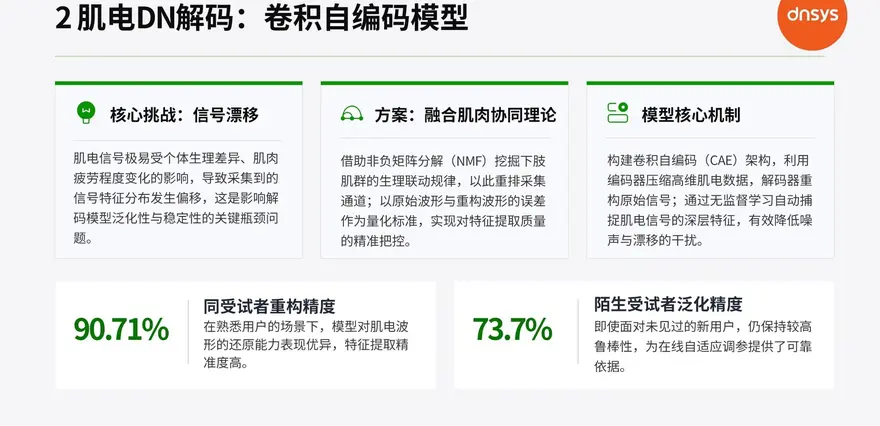
Figure: Schematic diagram of the multi-layered controlled experiment platform setup, featuring a distributed IMU array for individual posture capture. (Mentioned in the video)
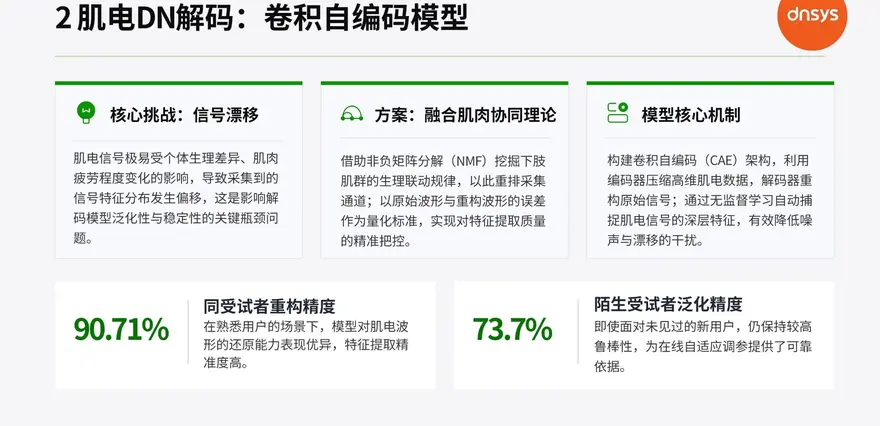
Figure: A muscle activation heatmap comparison between the traditional fixed joint torque group (left) and the DNCS dynamic solution group (right) during level-ground walking and uphill climbing. (Mentioned in the video)
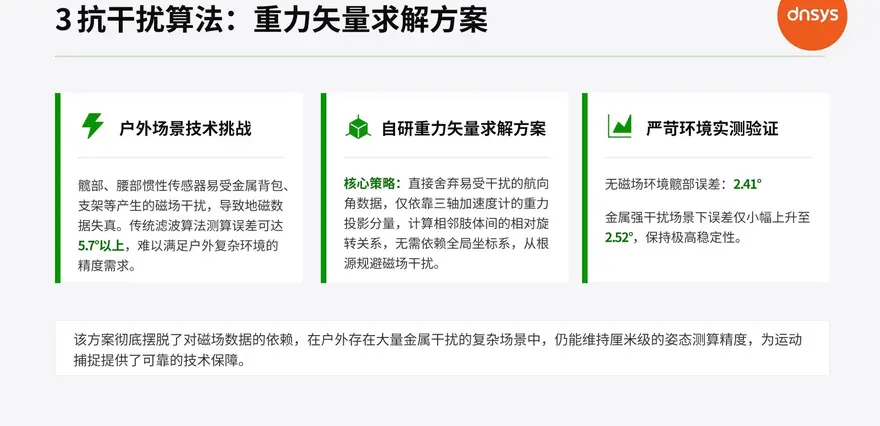
Figure: Real-time trend graph comparing fluctuations in metabolic consumption data (METs) during the system validation process. (Mentioned in the video)
Figure: The system experimental rig and a subject wearing the equipment, showcasing the multi-module response latency and tracking accuracy. (Mentioned in the video)
Competitor Product Comparison and Future Outlook: Who Will Capture the Boom in consumer-grade exoskeleton Market?
While DNCS has presented a technical architecture that can be considered perfect, the ultimate leap for the entire "consumer-grade exoskeleton" industry still requires joint efforts from the industrial and academic sectors to drive multi-scenario implementation.
The current race is flourishing: companies like Hypershell, which focuses on outdoor activities, are committed to launching lightweight, blade-style leg exoskeletons, attempting to reduce the overall weight to under 2kg (data from public industry sources). Meanwhile, veteran players like Aoshark (Aoshark) and ChengTian are continuously gaining ground in rehabilitation exoskeletons and general industrial lumbar / back assist.
However, the fundamental technical challenge faced by all is the same. Although Aoshark's flagship industrial-grade lumbar / back assist shines in logistics and handling scenarios, it remains limited by traditional static parameter tuning schemes when ordinary consumers undergo continuous, long-distance gait changes. A true consumer-grade exoskeleton—one that the public can afford, wear comfortably, and perceive as "completely unnoticeable"—must find a balance between lightweight structural design and edge-side AI computing power.
If consumer-grade products truly want to reach the mass market (such as the general mass sports scenarios explored by brands like Explorer), future product definitions must incorporate two core upgrades: First, focus on multi-modal fusion on the sensing end to improve intent recognition accuracy, allowing the machine to better understand every subtle posture of the user. Second, comprehensively promote the lightweight deployment of self-adaptive algorithms, achieving "rapid personalization adaptation for all users" on ultra-low-power chips.
The future "three-step" evolution roadmap for the DNCS system is worth watching: upgrading multi-modal fusion sensing, optimizing adaptive algorithms for rapid adaptation, and promoting deep implementation in medical and multi-scenario fields. When these top-tier academic achievements cross the chasm of engineering and mass production, the problem of muscle cramps during outdoor hiking might truly be solved.
Caption: DNCS's future planned multi-modal fusion sensing scheme and the blueprint for medical and multi-scenario implementation. (Mentioned in the video)
Caption: Demonstration of industrial-grade assistive exoskeleton products from Aoshark (Aoshark) and their gait linkage. (Mentioned in the video)
Caption: The combination of extreme lightweight leg exoskeletons practiced by brands like Hypershell with hiking / trekking assist scenarios. (Mentioned in the video)
__IMG3** Caption: A radar comparison chart of industry parameters for the weight and assist ratio of different exoskeleton product forms at the current stage. (Mentioned in the video)
Caption: Display of the actual application structure of carbon fiber materials in a human-machine integration system for lightweighting. (Mentioned in the video)
Summary: The ultimate form of an exoskeleton should be as "part of the human body"
Having sat through this hard-core technical briefing, the most exciting revelation isn’t the sheer number of powerful hardware sensors on display, but a fundamental paradigm shift in the human–machine interaction logic: moving from machines passively “tracking” human movements to actively predicting and converging on the body’s intent — a transition from mere following to true integration.
When battery life is no longer a burden that weighs down the legs, and when joint torque output becomes so smooth and silent it feels effortless, the “technology loop” envisioned by DNCS finally takes on a tangible soul.
This is more than a stunning showcase of advanced algorithms. It sends a clear signal to the market: consumer exoskeleton devices are on the verge of crossing the chasm, moving from cold, clinical rehabilitation equipment onto the mainstream consumer sports stage.
Caption: A technical roadmap showing how consumer-grade exoskeletons will evolve from single-purpose medical devices into broadly adopted sports-assist tools. (mentioned in video)
Caption: Comprehensive observations of gait synchronization and overall reductions in metabolic cost during hiking and heavy load trekking over complex terrain. (mentioned in video)
__IMG2** Caption: Visions of future soft-form exoskeletons that fully separate from rigid biomimetic structures, embracing flexible, deeply integrated designs. (mentioned in video)
Caption: A historical milestone diagram illustrating how human–robot integration will completely break away from traditional, monotonous, passive control paradigms. (mentioned in video)
Caption: A core demonstration of DNCS’s algorithm system applied to multi-terrain assessment and instant response in complex environments. (mentioned in video)
Caption: An integrated command flow pathway in which an LSTM system comprehensively captures human temporal data and coordinates with underlying hardware for execution.
Caption: Virtual 3D mapping generation of human posture and movement, powered by a multi-sensor array. (mentioned in video)
Caption: Leading-edge validation of consumer-grade exoskeleton capabilities at the level of vestibular neural perception and feedback, achieved by DNCS. (mentioned in video)
Caption: Final comprehensive loop demonstrating performance leaps in consumer-grade exoskeletons, validated jointly by academia and industry. (mentioned in video)
Caption: The potential prospects of deploying large-model computing power on low-energy microcontroller platforms. (mentioned in video)
Caption: A bold future vision where hiking / trekking assist exoskeletons act like everyday gear, seamlessly supporting multiple outdoor scenarios without extra burden. (mentioned in video)
Top Community Comments
1. 1. 1. 1.
The introduction of deep learning and CAE models is truly ingenious. A convolutional autoencoder-based filtering de-noising approach like DNCS feels straight out of sci-fi. The problem, though, is the massive computational power this extensive algorithm demands—can future consumer-grade microcontrollers really run it smoothly while achieving millisecond-level low latency?
Media Interpretation: This comment pinpoints the biggest pain point in transitioning academic solutions to industry—the "edge computing wall." No matter how sophisticated the algorithm, it still requires low-power chips, which is also the necessary path for all AI hardware products toward commercialization.
1. 1. 1. 1.
This closed loop of mechanical actuation and intent prediction sounds almost too perfect. If computing power can fully resolve latency issues, should this system allow for an ideal combination of battery life and instantaneous joint torque? However, it remains unknown exactly how light the device can become. If people wear it for mountain climbing, with lower limbs equipped with plenty of motors and batteries, uncontrollable weight will definitely lead to a disaster.
Media Interpretation: Viewers keenly focus attention on consumer-grade "load-bearing concerns." Reducing overall device weight depends on carbon fiber composites, which is the entry ticket for exoskeleton products to move fully into mainstream consumer markets.
1. 1. 1. 1.
Current products like those by Aoshark already show effective results in industrial logistics handling. If assisted by DNCS's new algorithm featuring automatic interaction resistance dynamic adjustment, could it also become a powerful assistive tool in rehabilitation centers for patient treatments in the future?
Media Interpretation: The comments touch upon imaginative speculation regarding product scenario reshaping. Reinforcement learning algorithms with dynamic parameter adjustment inherently possess multi-scenario adaptability. Transitioning from strictly defined industrial auxiliary applications to medical rehabilitation fields is eagerly anticipated due to its promising technical compatibility.
1. 1. 1. 1.
In the current environment, asking ordinary people with zero experience to wear highly mechanical exoskeletons for mountain climbing makes me quite concerned about discomfort caused by flexible materials and gait confusion due to complex lower-limb self-balancing adjustments.
Media Interpretation: Besides providing walking assist, exoskeletons' disturbance of users' own neural feedback and associated "learning curves" are equally hidden difficulties determining interaction friendliness.
1. 1. 1. 1.
Given LSTM models predicting movement timing patterns and EMG signal decoding, when coping with dynamic resistance, will the SAC reinforcement learning algorithm enable this exoskeleton itself to possess certain "self-healing abilities", while also delivering a highly compliant mechanical experience?
Media Interpretation: The meme comment reflecting maxed-out expectations shows deep anticipation within the geek community for next-generation smart wearable devices genuinely possessing "external muscles and AI awareness."
One-Sentence Summary
This hard-core briefing isn’t just an algorithmic leap that helps users breeze past the notorious “dragging feeling” bottleneck; it’s a manifesto for the consumer-grade exoskeleton’s transformation from a clunky device into an AI companion that actually understands you. Essential reading for tech geeks and makers of assistive wearables alike.
About this article: part of Chinese-Made Exoskeleton Review Archive — an independent, regularly updated English archive of reviews of consumer exoskeletons made in China, edited from publicly available video transcripts. Not an official manufacturer page.
For inquiries and purchasing, contact lonlonago@foxmail.com. More in Tech & Design · All articles.